▶ P01 — SELF-PARKING RC CAR · MECHATRONICS

Self-Parking RC Car

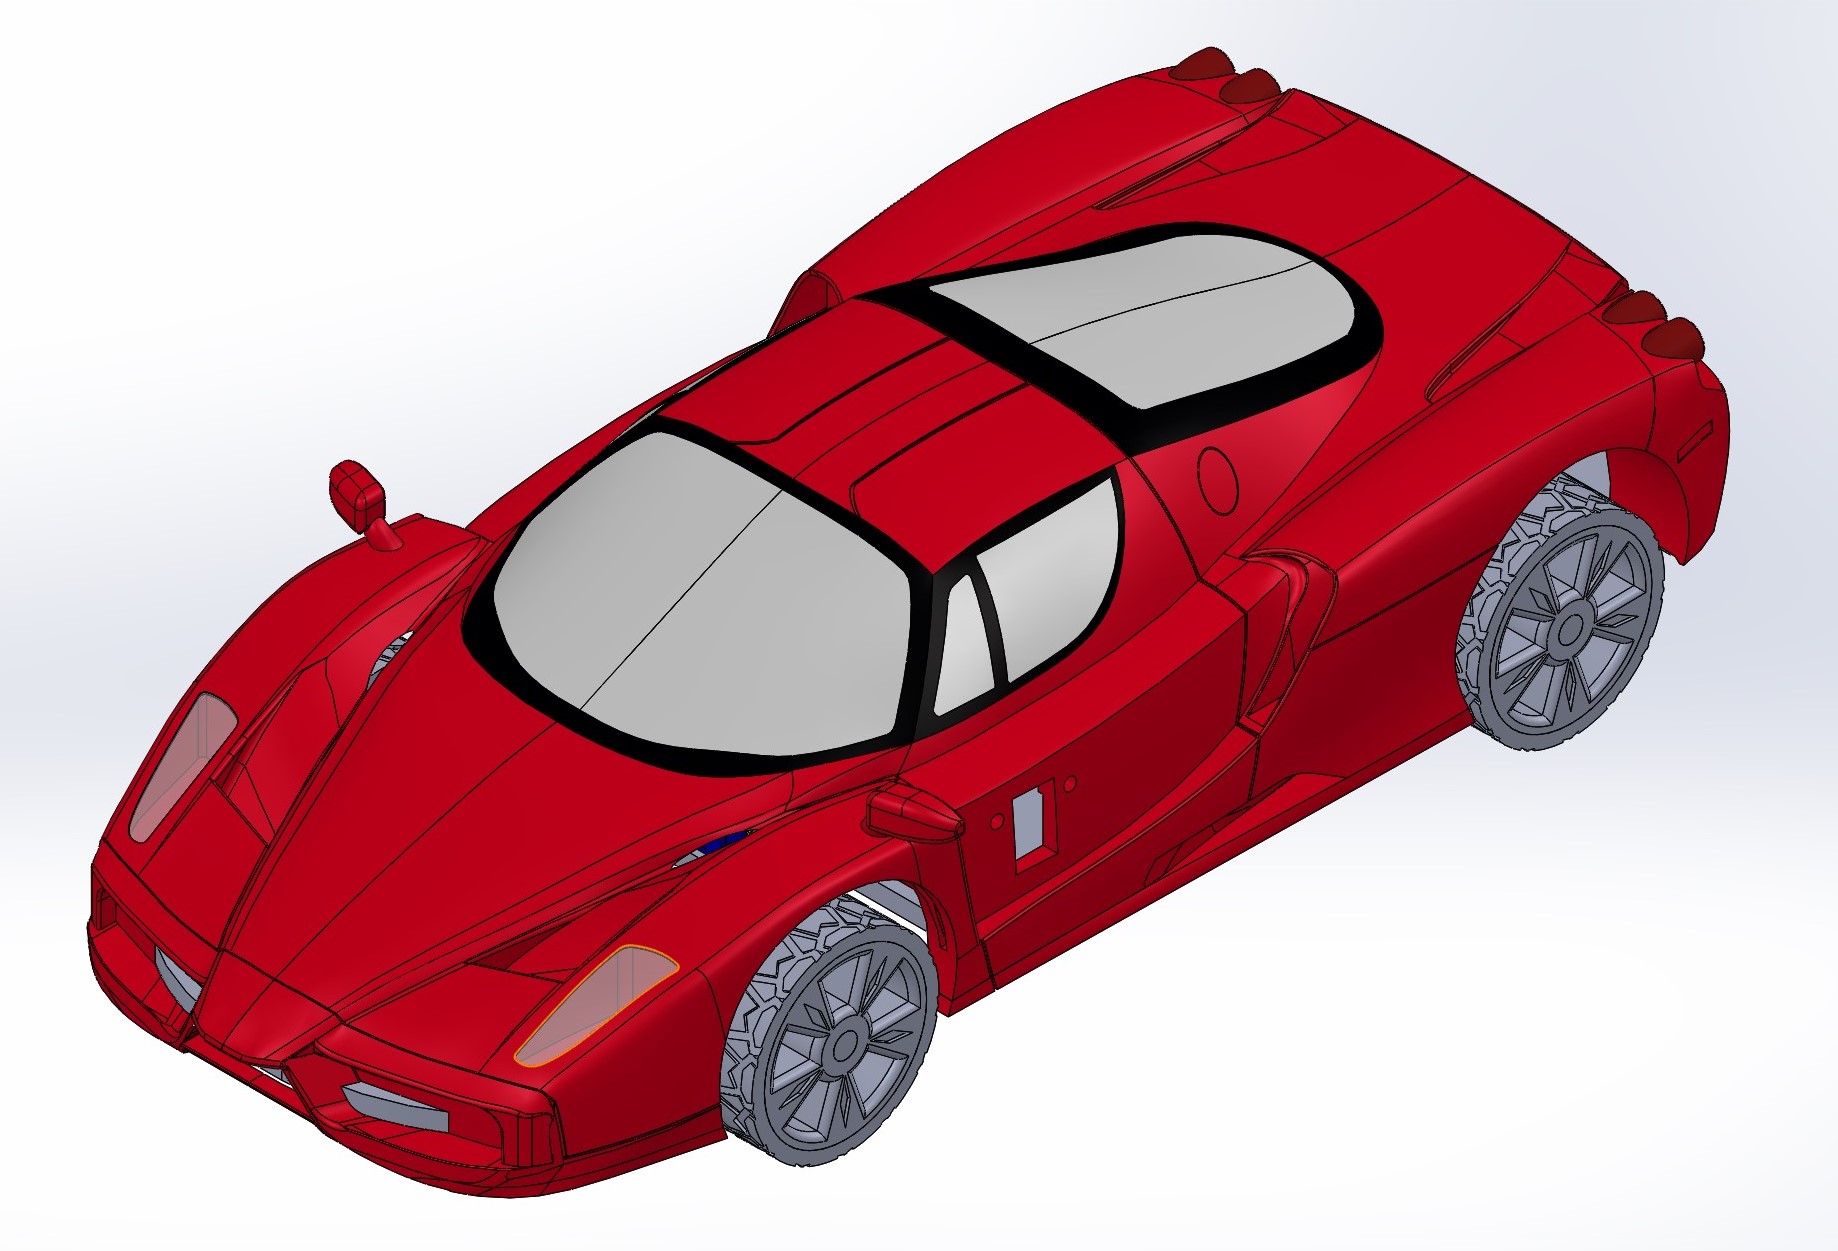
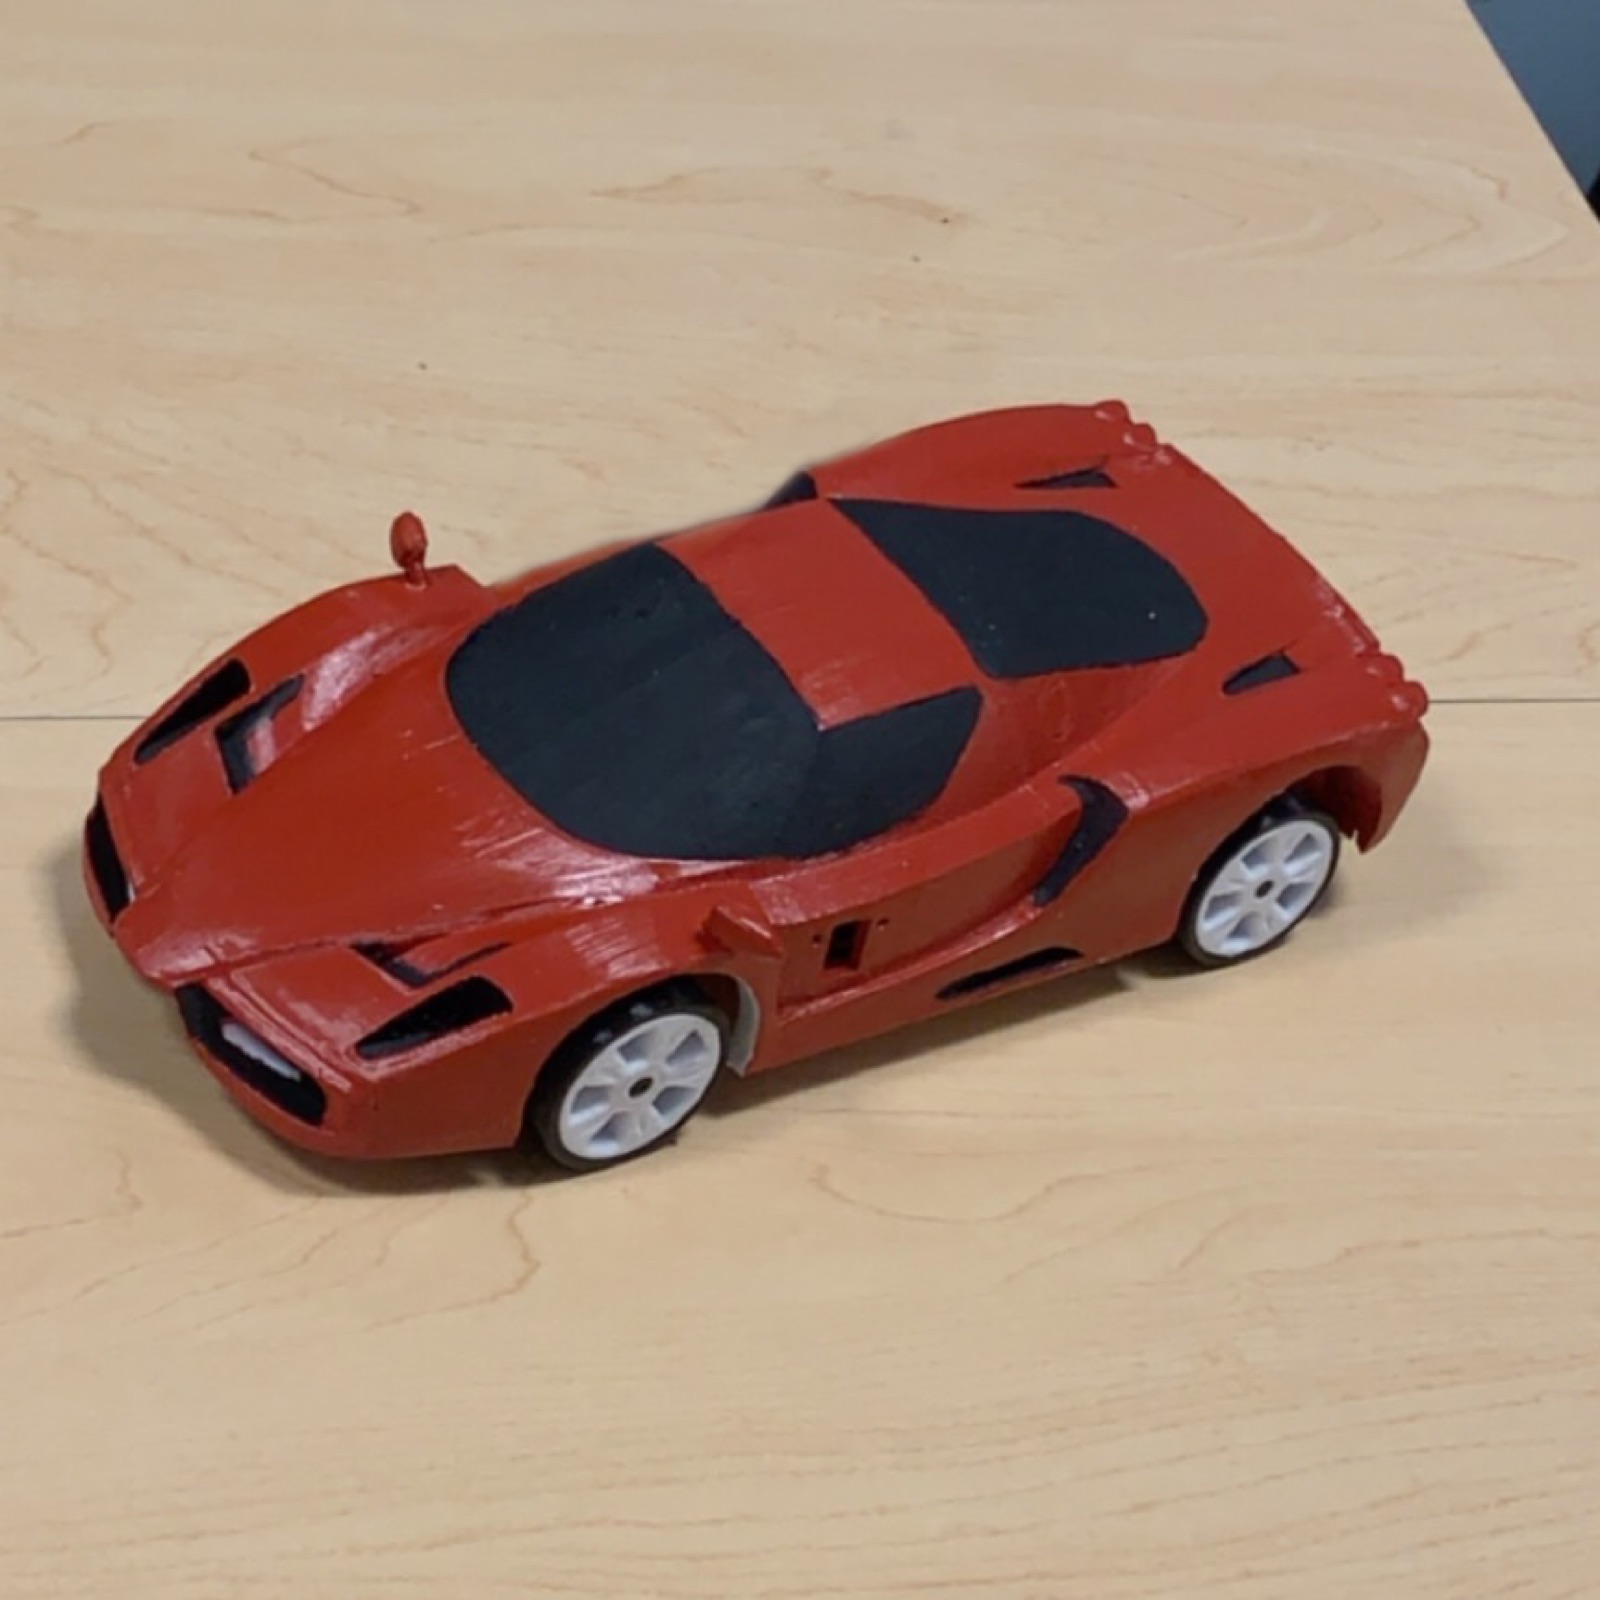
Remote-controlled car with autonomous self-parking on a modified 3D-printed Enzo Ferrari body. Brushless drivetrain, 4 laser distance sensors, a custom breakout PCB, and Bluetooth smartphone control.

4× VL53L0X ToF laser 4× brushless DC ESP32 Bluetooth

Autonomous mode: parallel-parks between two obstacles with no human input.

Mechatronics — End-to-End Build

Starting from a modified 3D-printed Enzo Ferrari body, this project integrates a full mechatronic system: brushless DC drivetrain, custom breakout PCB, laser obstacle detection, and Bluetooth control from a smartphone app.

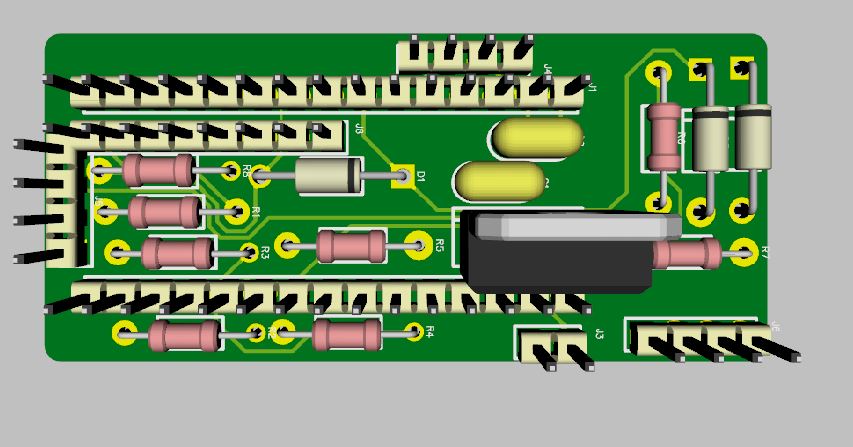
The autonomous parking mode uses four VL53L0X time-of-flight laser sensors to detect two flanking obstacles and execute a parallel parking maneuver without any human input. A custom breakout PCB inside the body handles power regulation, sensor interfacing, and the tail lights.

Motors
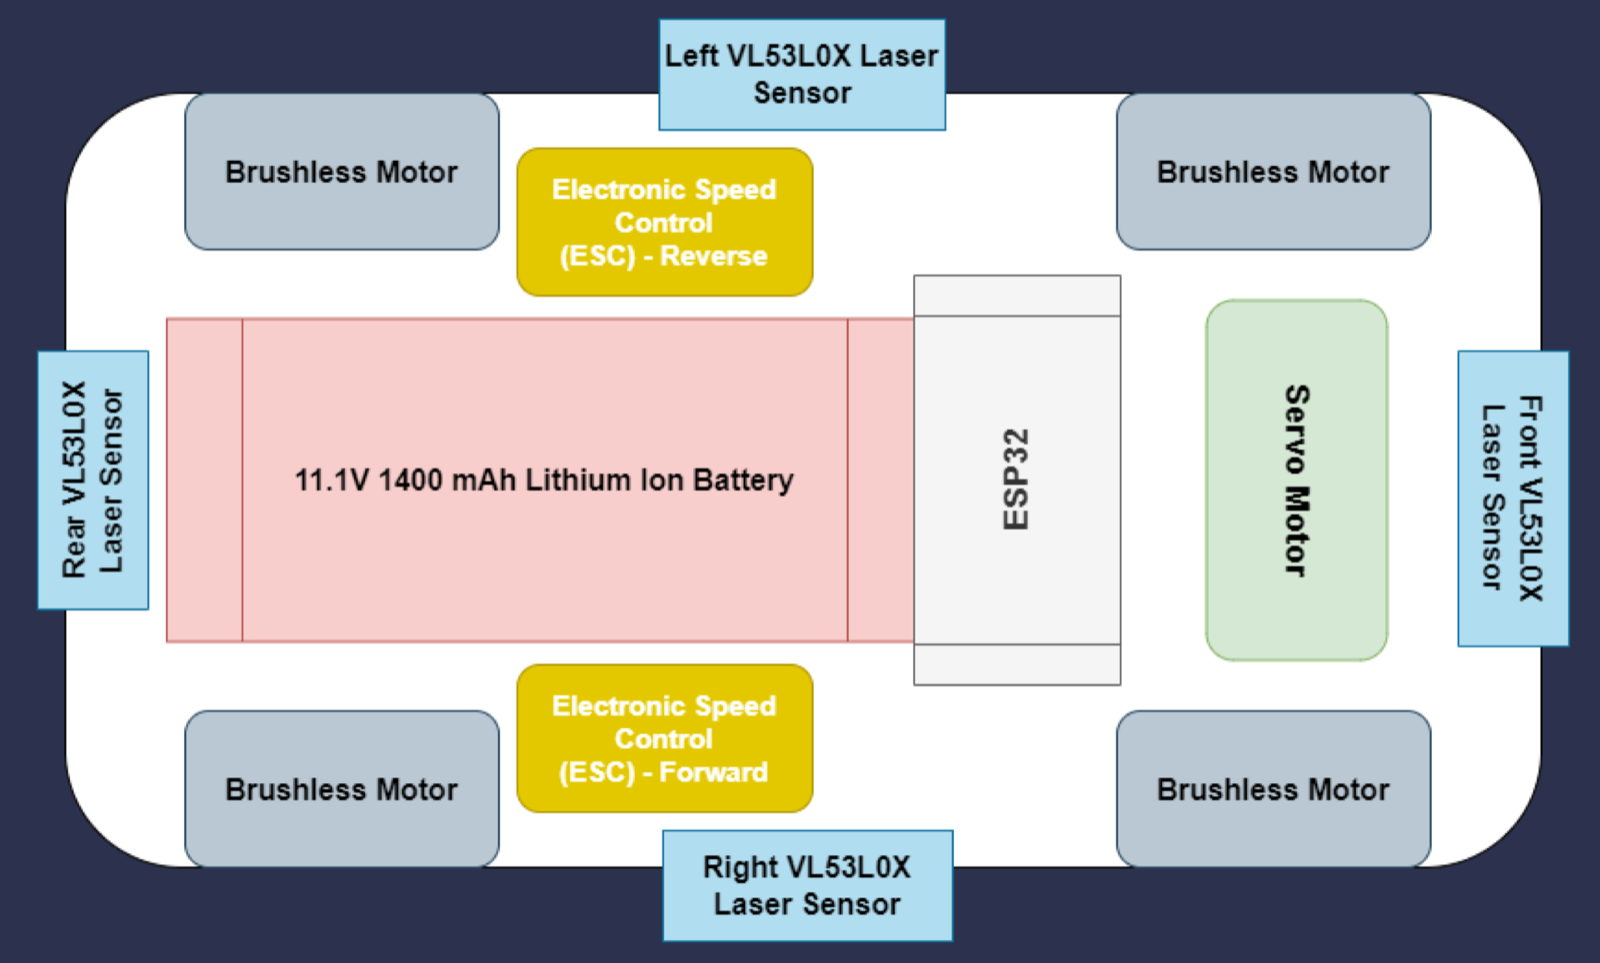
4× 10,000 RPM Brushless DC
ESCs
2× 40A Quadcopter (One-Way)
Battery
1400 mAh LiPo
Steering
20 kg Servo Motor
Sensors
4× VL53L0X ToF Laser
Wireless
ESP32 Bluetooth + Telemetry
PCB
Custom Breakout Board
Body
3D-Printed Enzo Ferrari
Course
Mechatronics (2019) → Adv. Microprocessors (2022)
Collaborators
Matthew Mazalewski · Kim Tran · Wyatt Van Orden
Engineering Breakdown

◈

Autonomous Parallel Parking

4 laser distance sensors detect flanking obstacles and trigger a full autonomous parallel parking sequence — zero human input required.

◈

Brushless Drivetrain

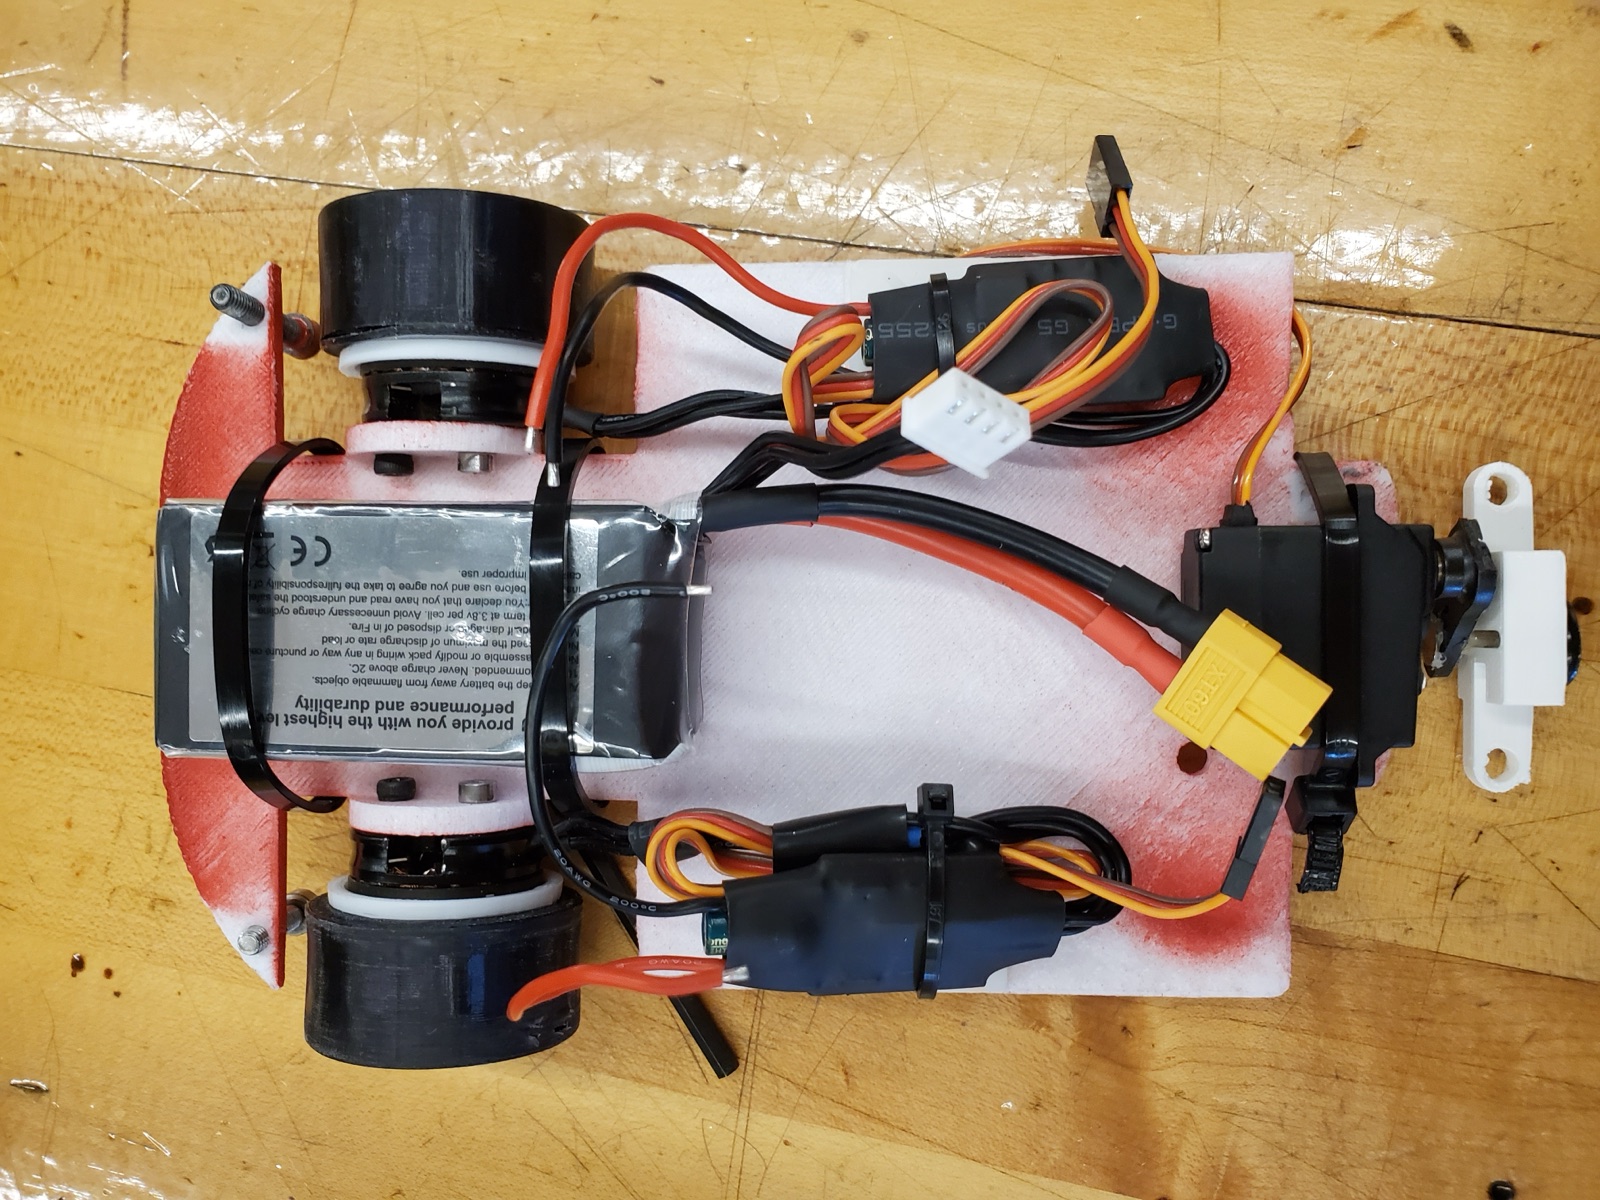
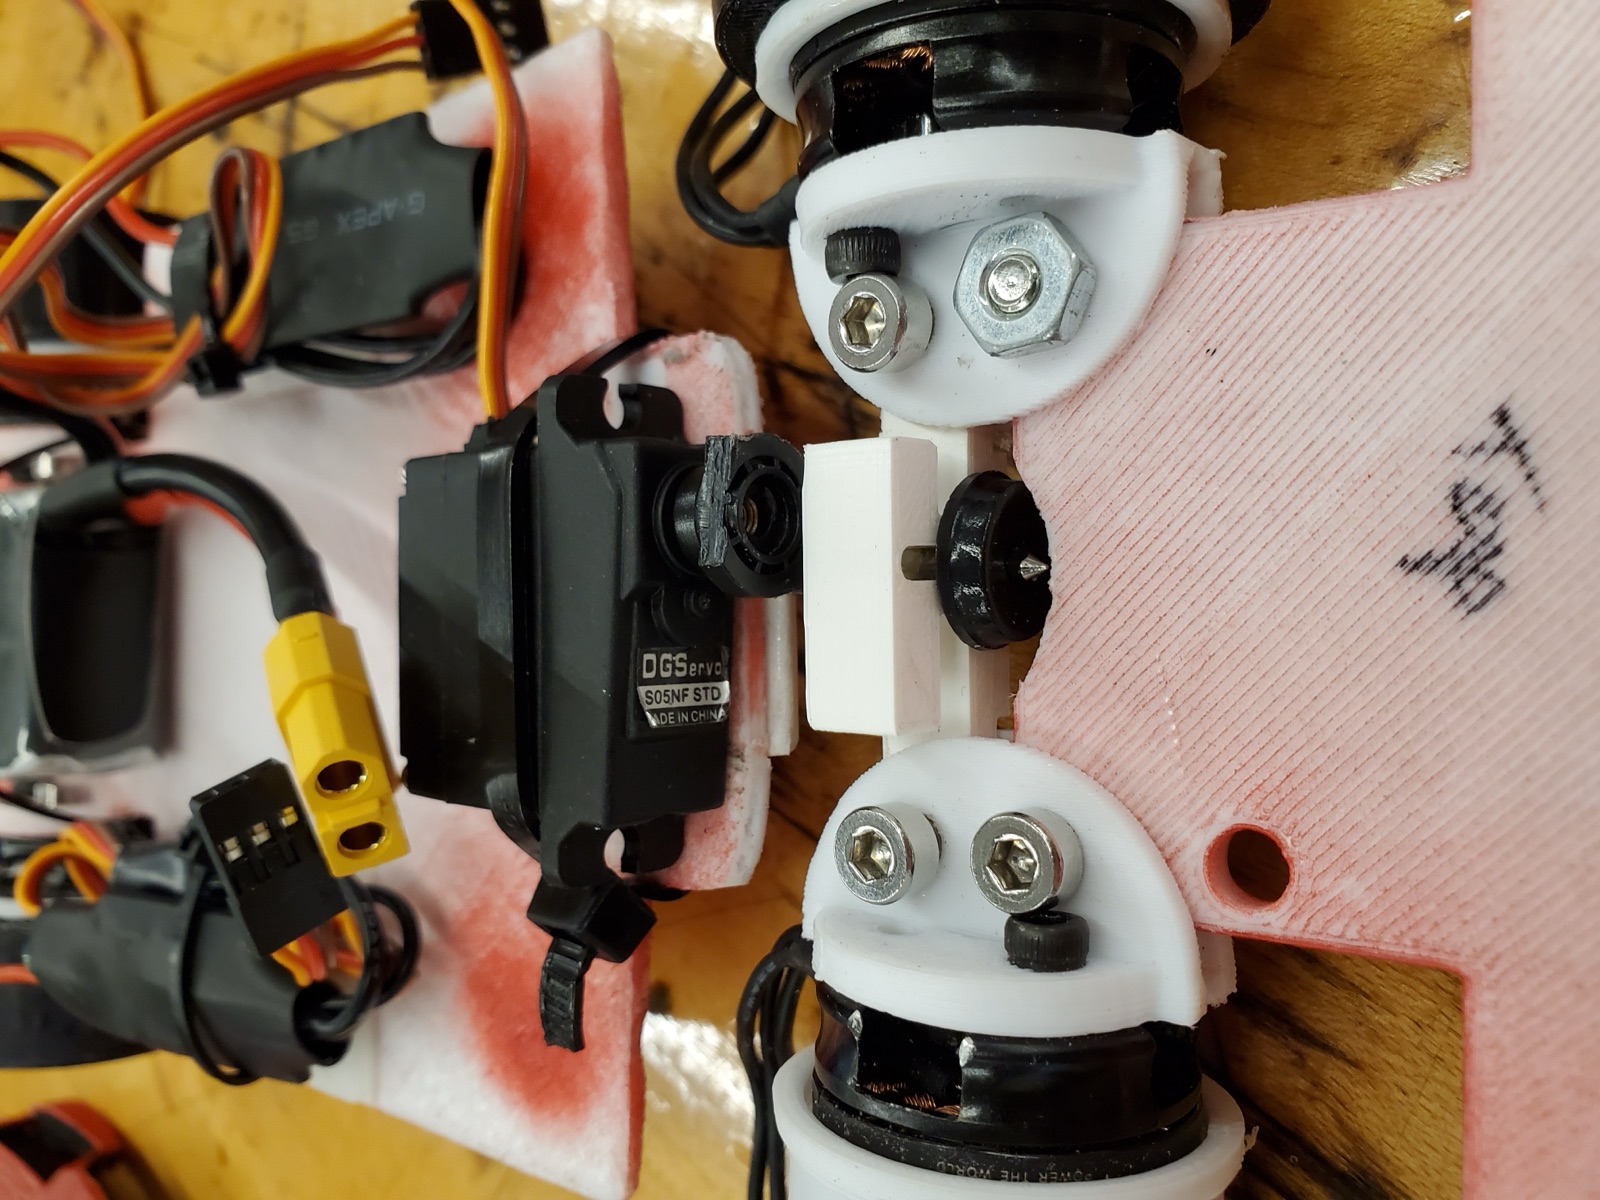
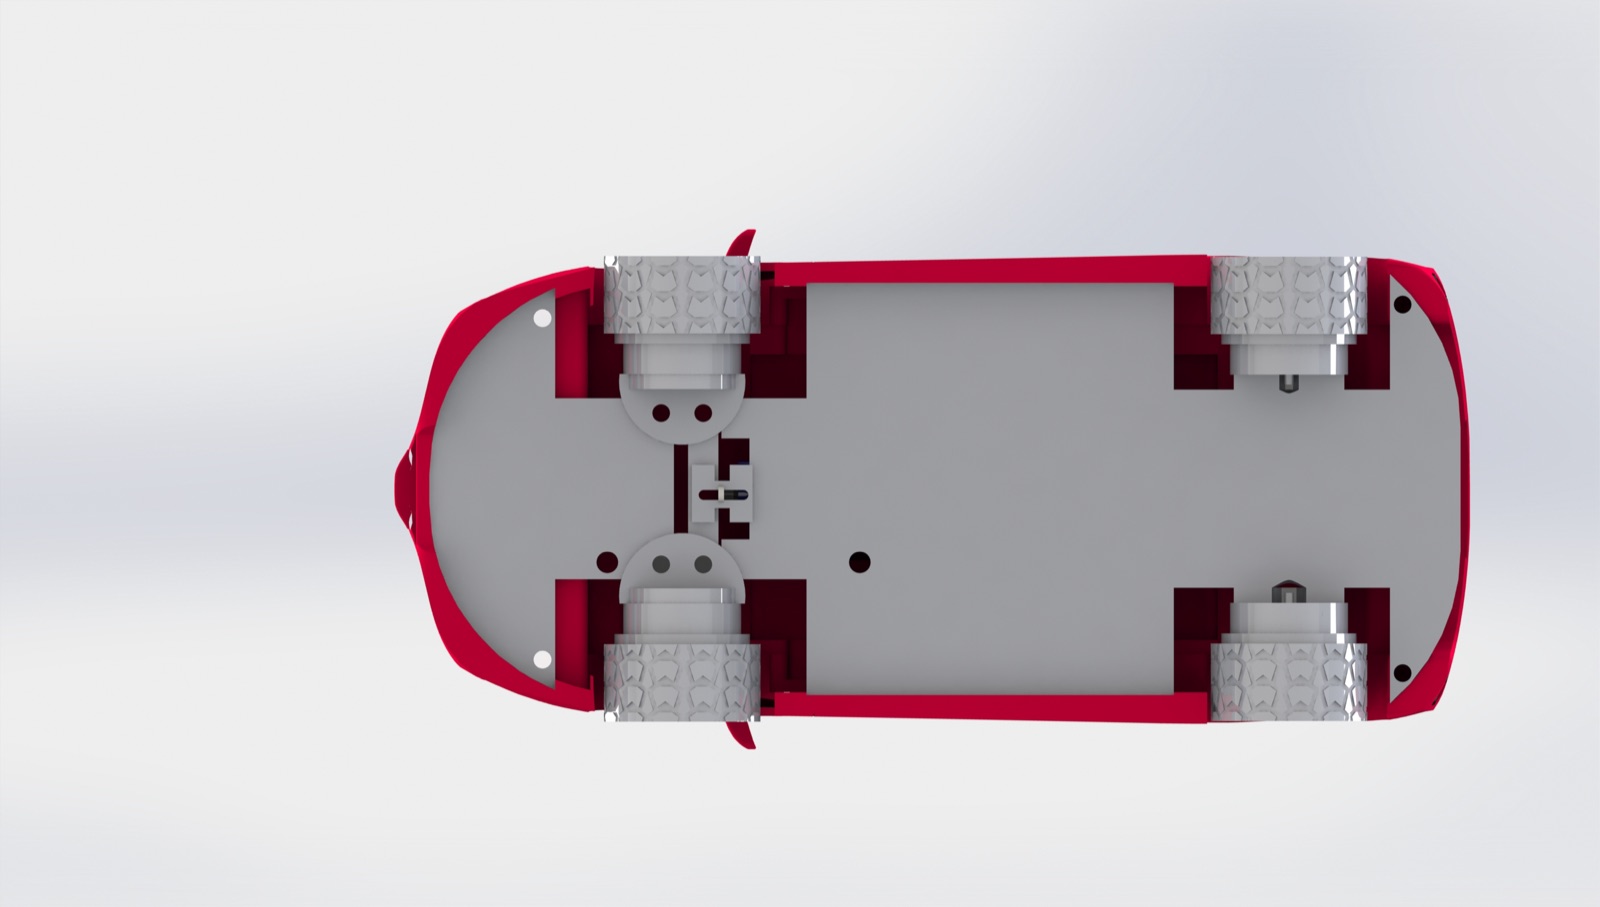
Four 10,000 RPM brushless DC motors on a 1,400 mAh LiPo. The 40A ESCs were one-direction quadcopter units, so forward and reverse are split across the axles: the rear motors drive the car forward, and the front motors are wired in reverse to back it up.

◈

Custom Breakout PCB

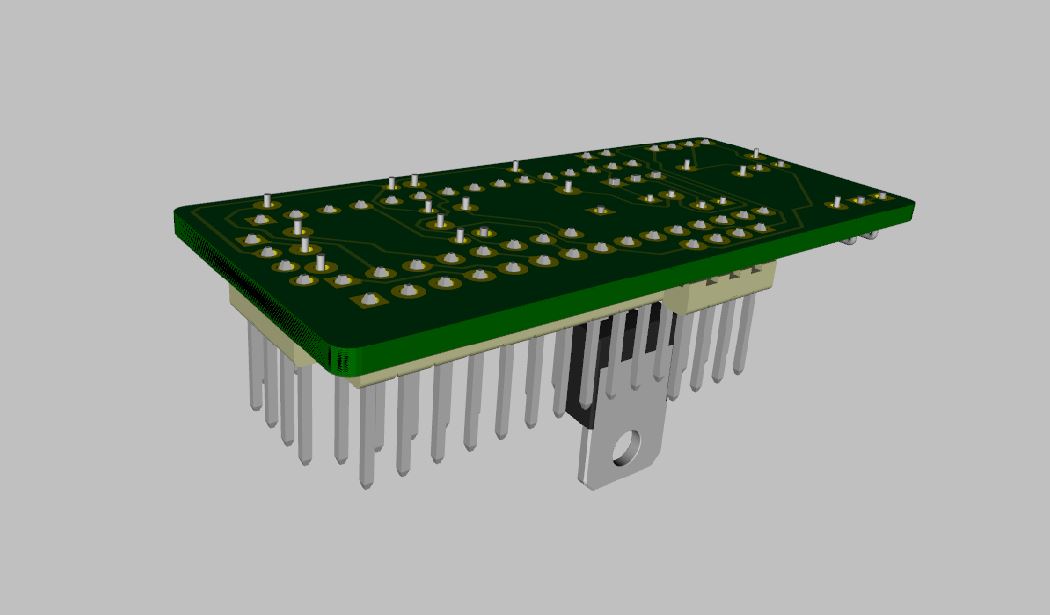
Designed a custom through-hole breakout board that mounts inside the body, handling battery-to-5V regulation, I²C sensor interfacing, and tail-light drive.

◈

Bluetooth RC Control

The ESP32 handles the Bluetooth link to a smartphone app, carrying manual RC control and telemetry alongside the autonomous parking mode.

◈

3D-Printed Ferrari Body

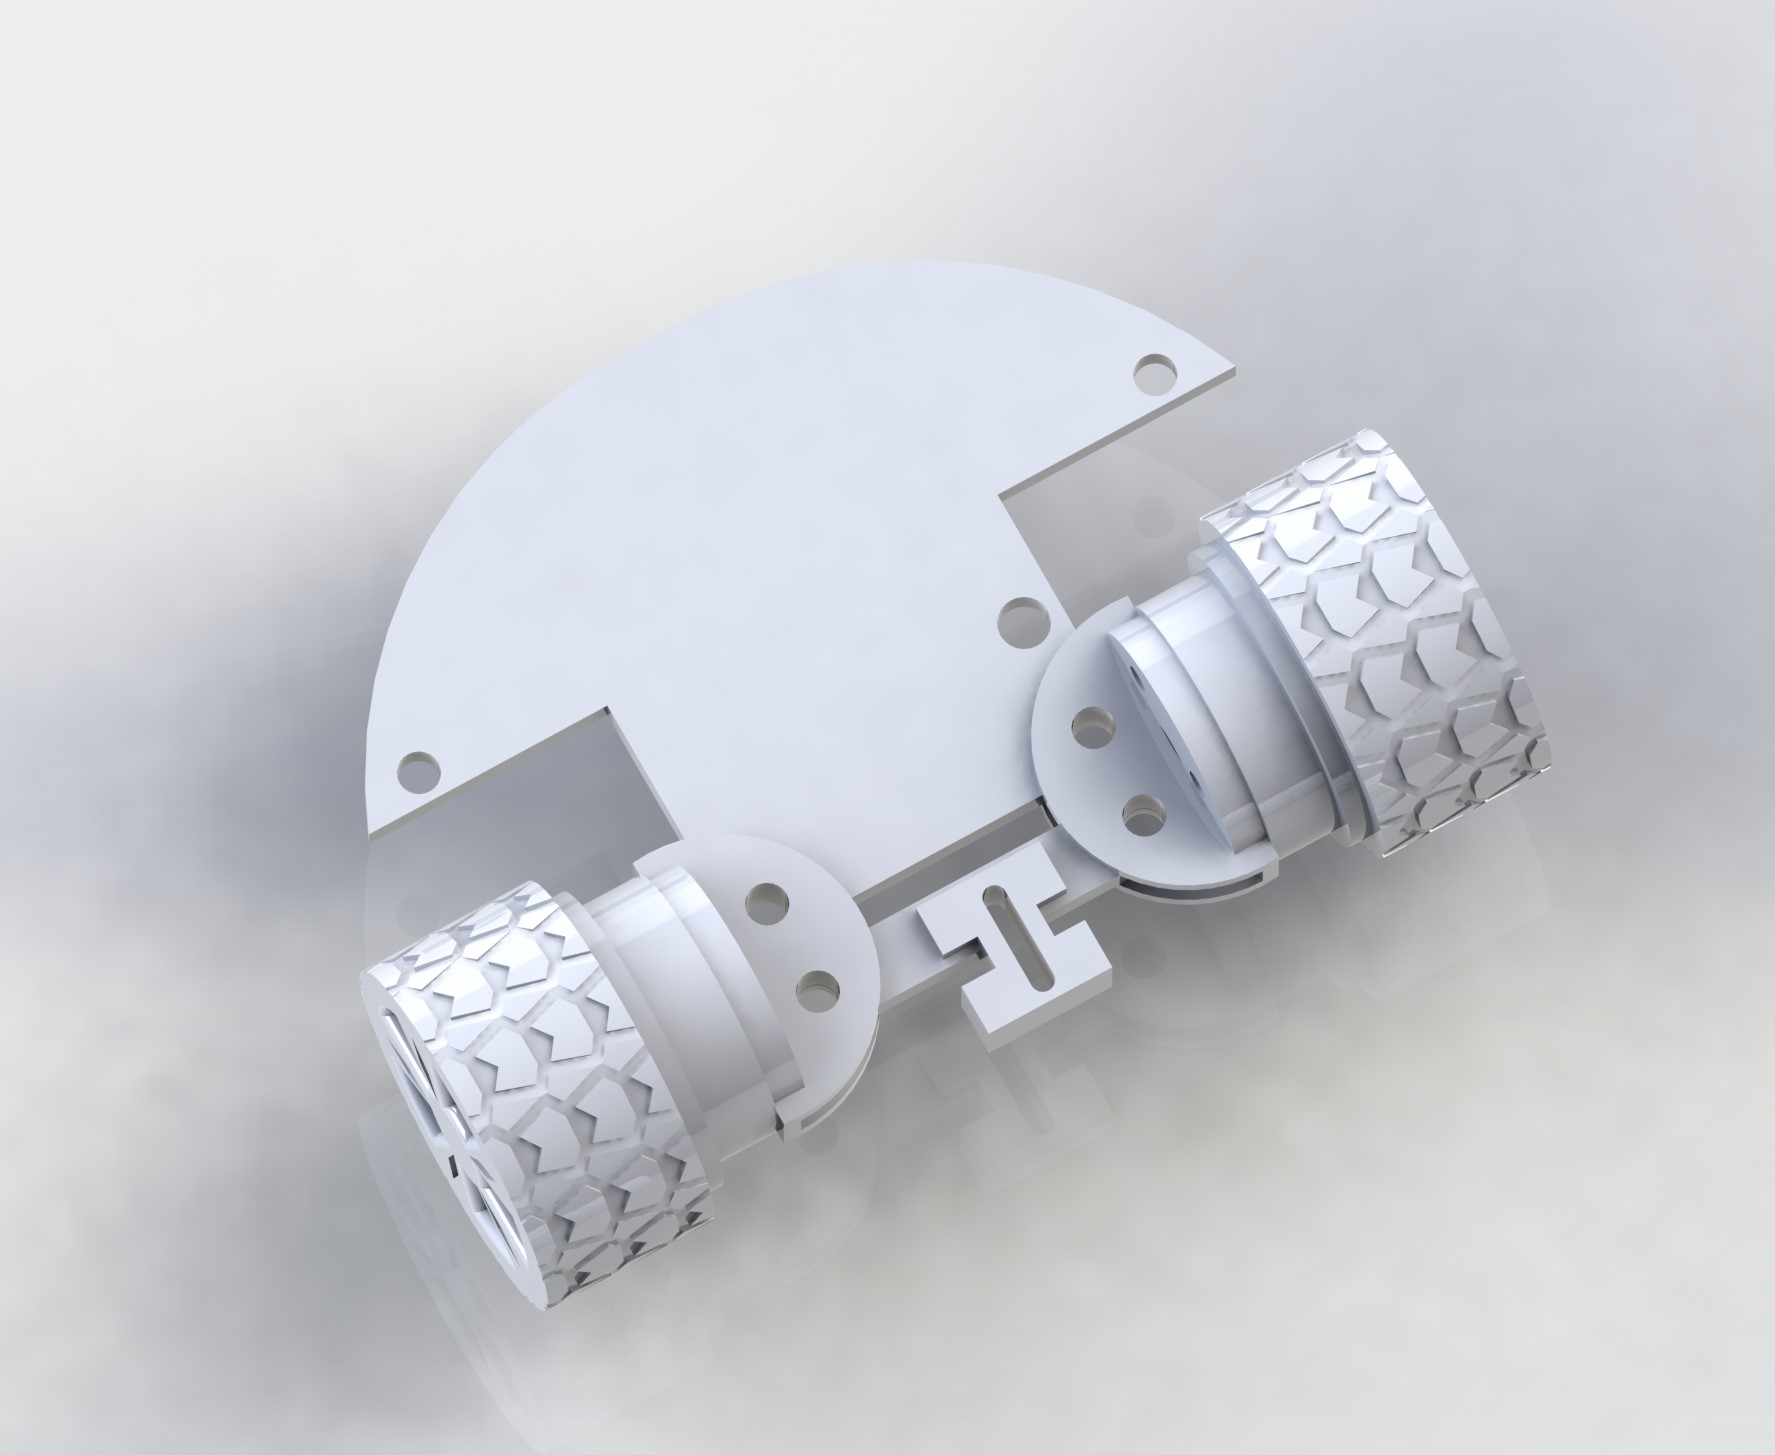
Designed and fabricated the car around a modified 3D-printed Enzo Ferrari model, engineering custom mounting and clearances for all subsystems.

◈

20 kg Servo Steering

High-torque 20 kg servo motor provides precise steering authority for both manual RC control and the autonomous parking maneuver sequences.

Project Files

Capabilities Used

// ELECTRICAL
DipTrace Embedded Design SMT Stenciling PCB Design Fabrication Diagnosis
// HARDWARE
SMT Assembly Oscilloscope
// MECHANICAL
SolidWorks FDM / SLA 3D Print Machine Shop
// FIRMWARE
Embedded C PWM / Timers UART
Next project · 2 / 5 Guitar Effect Pedal Series →