Mechatronics — End-to-End Build
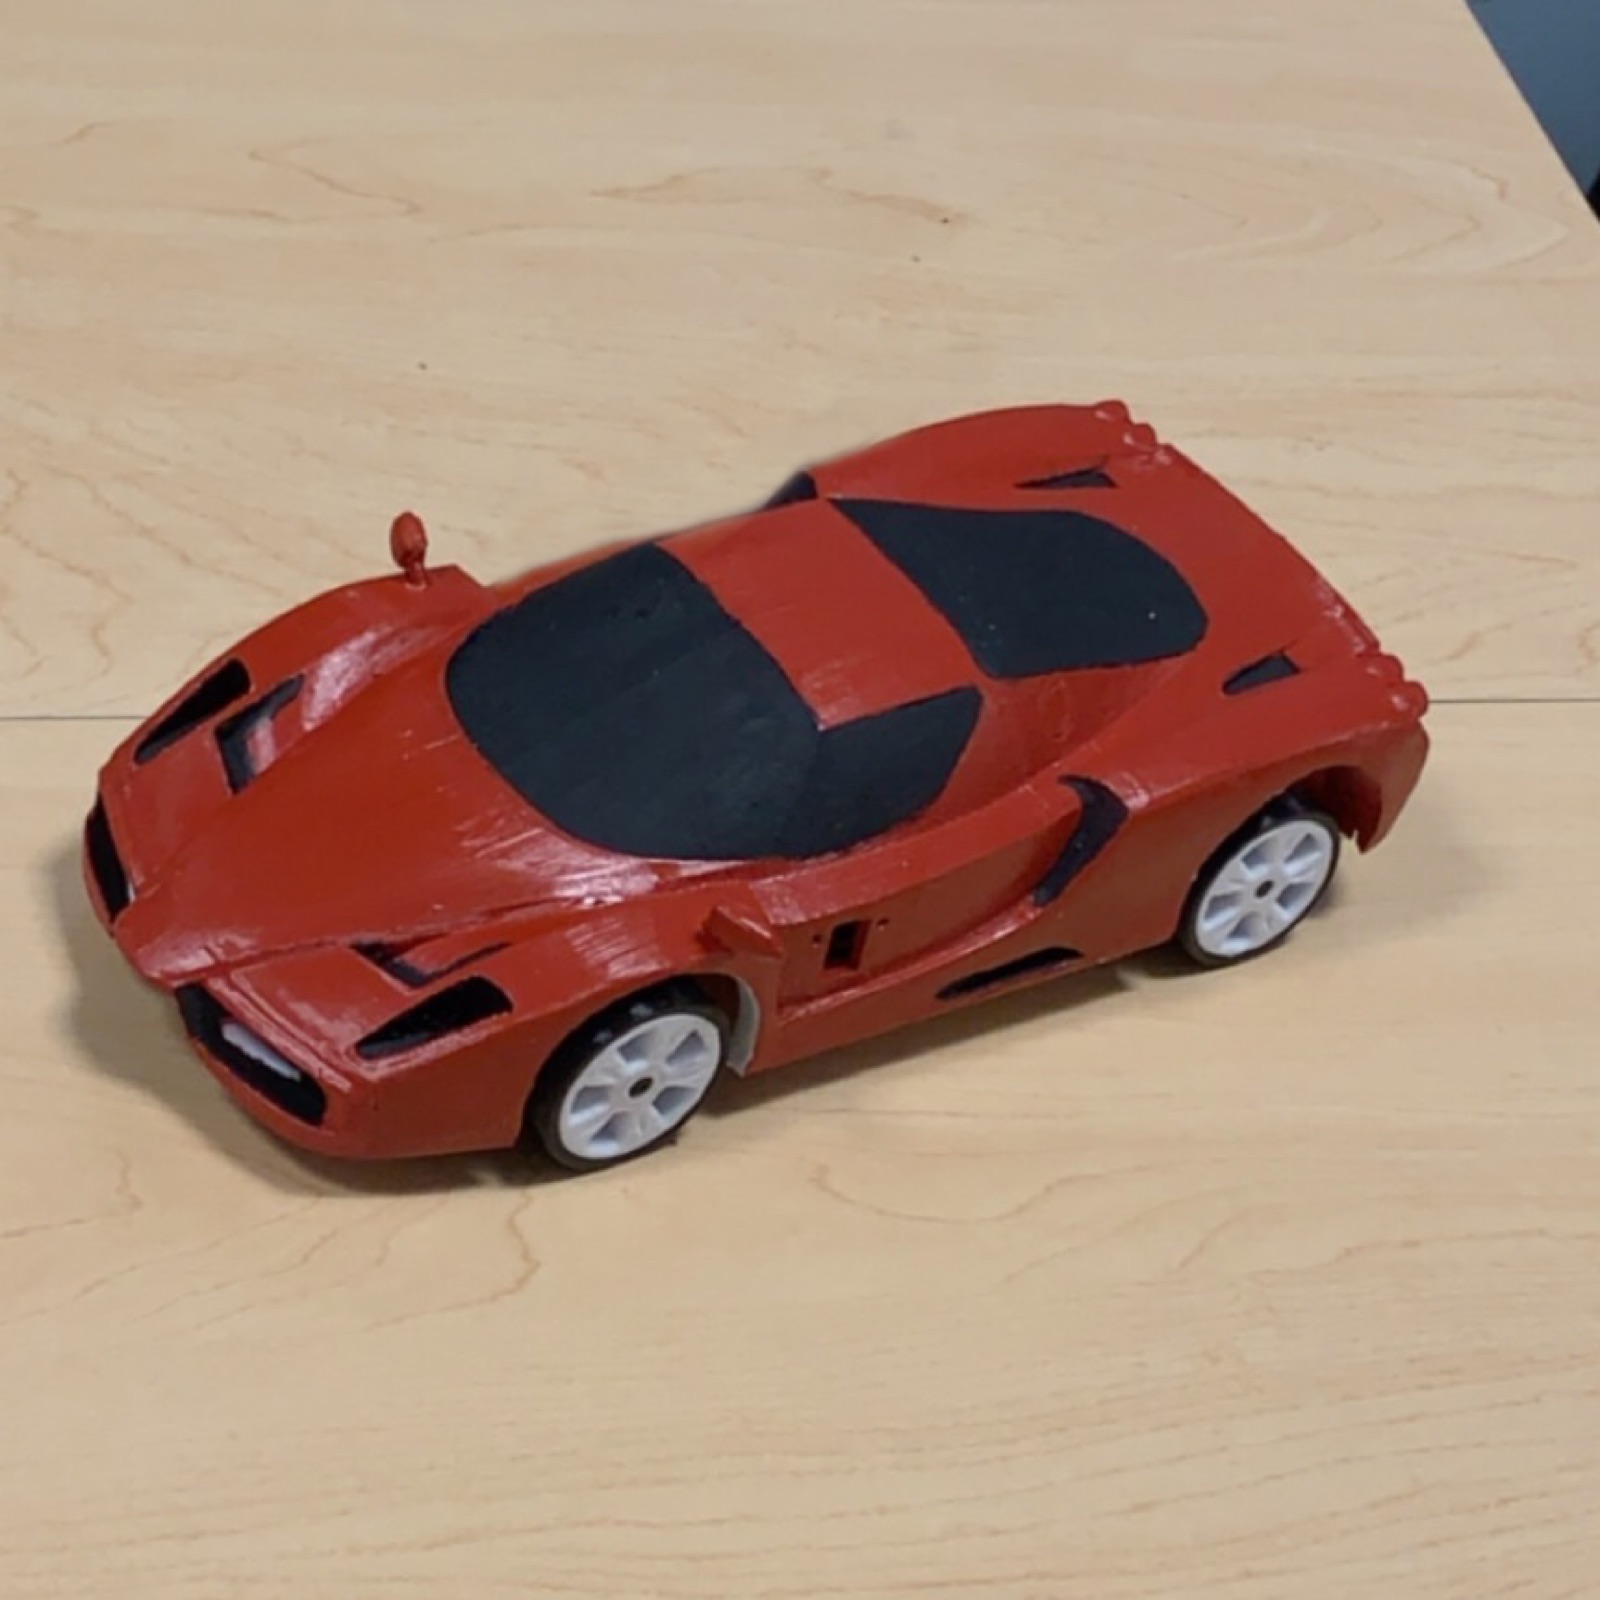
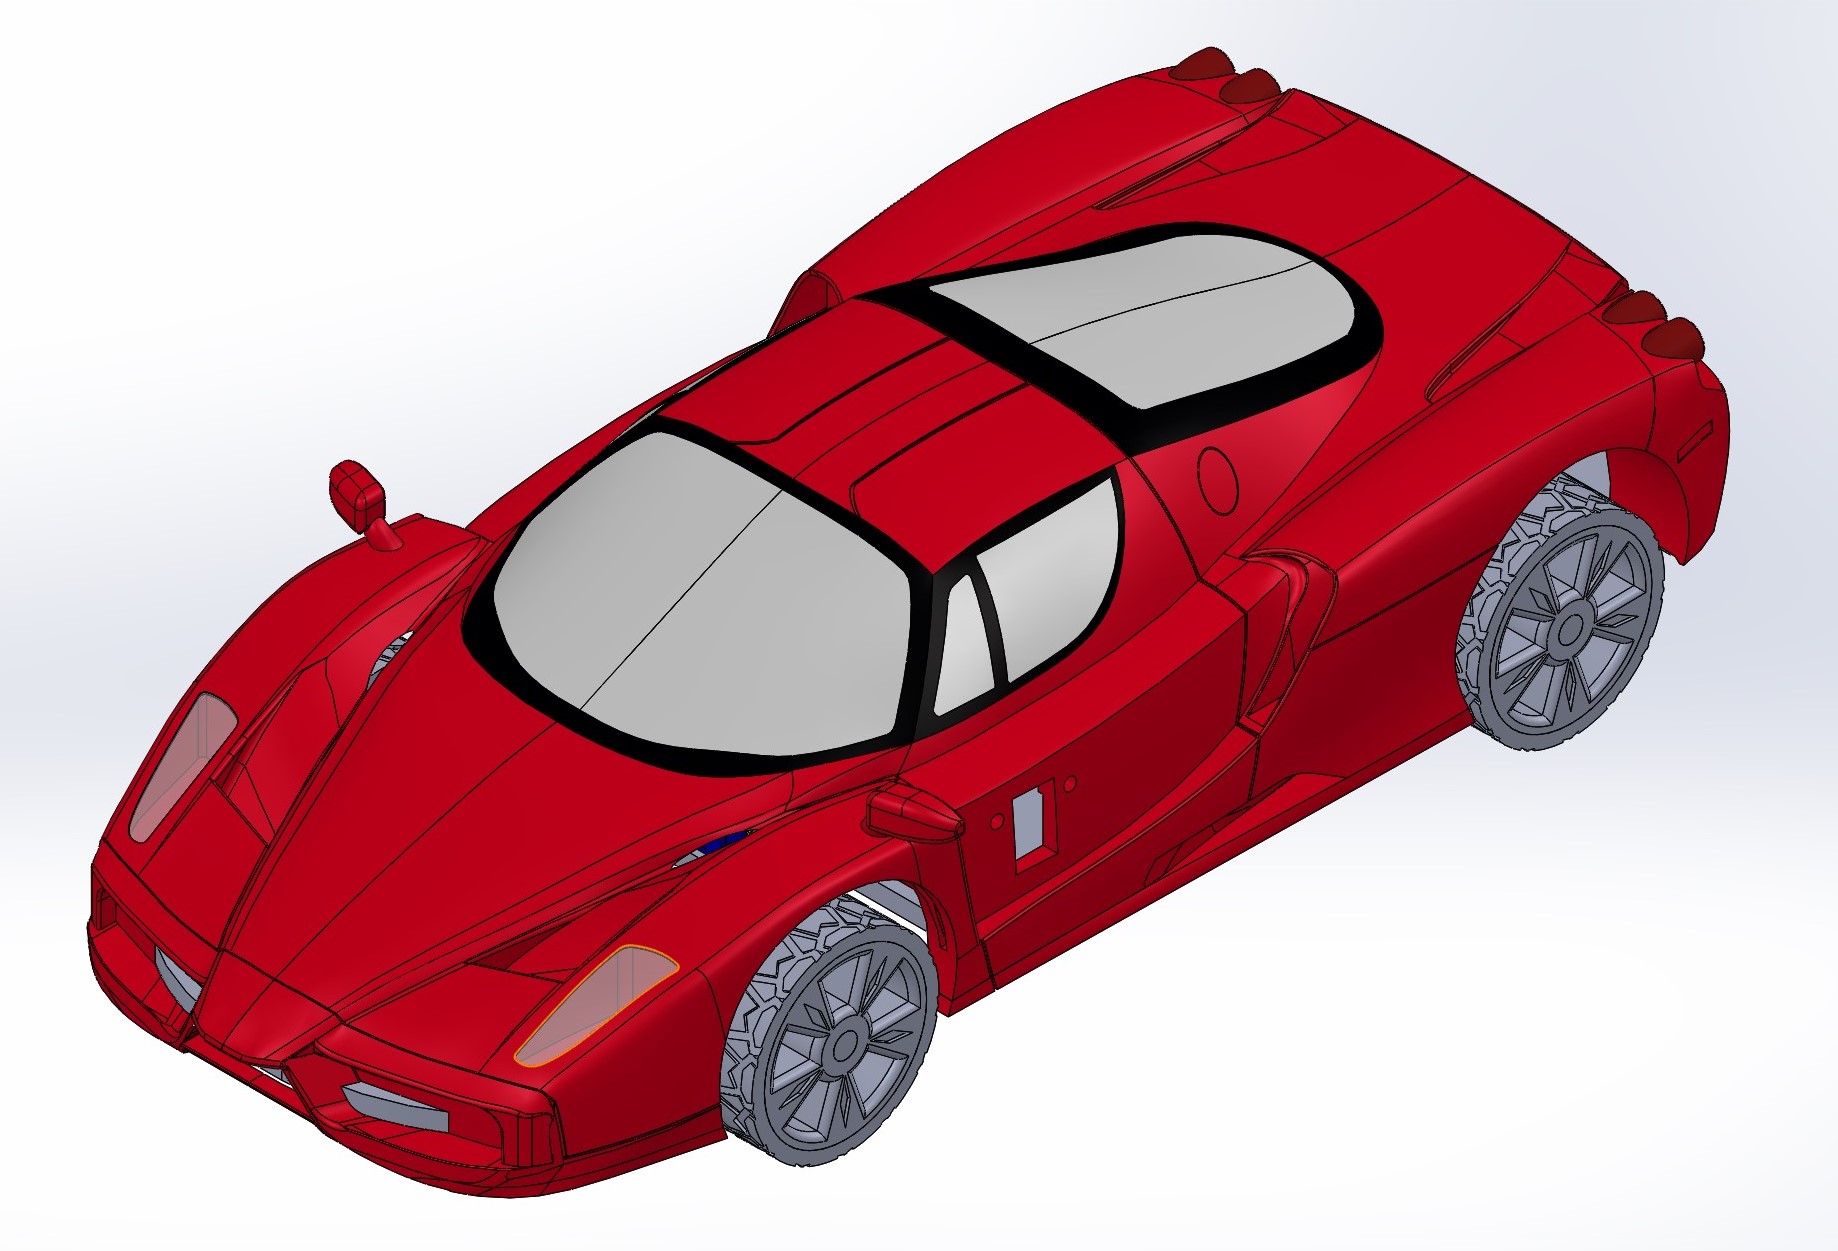
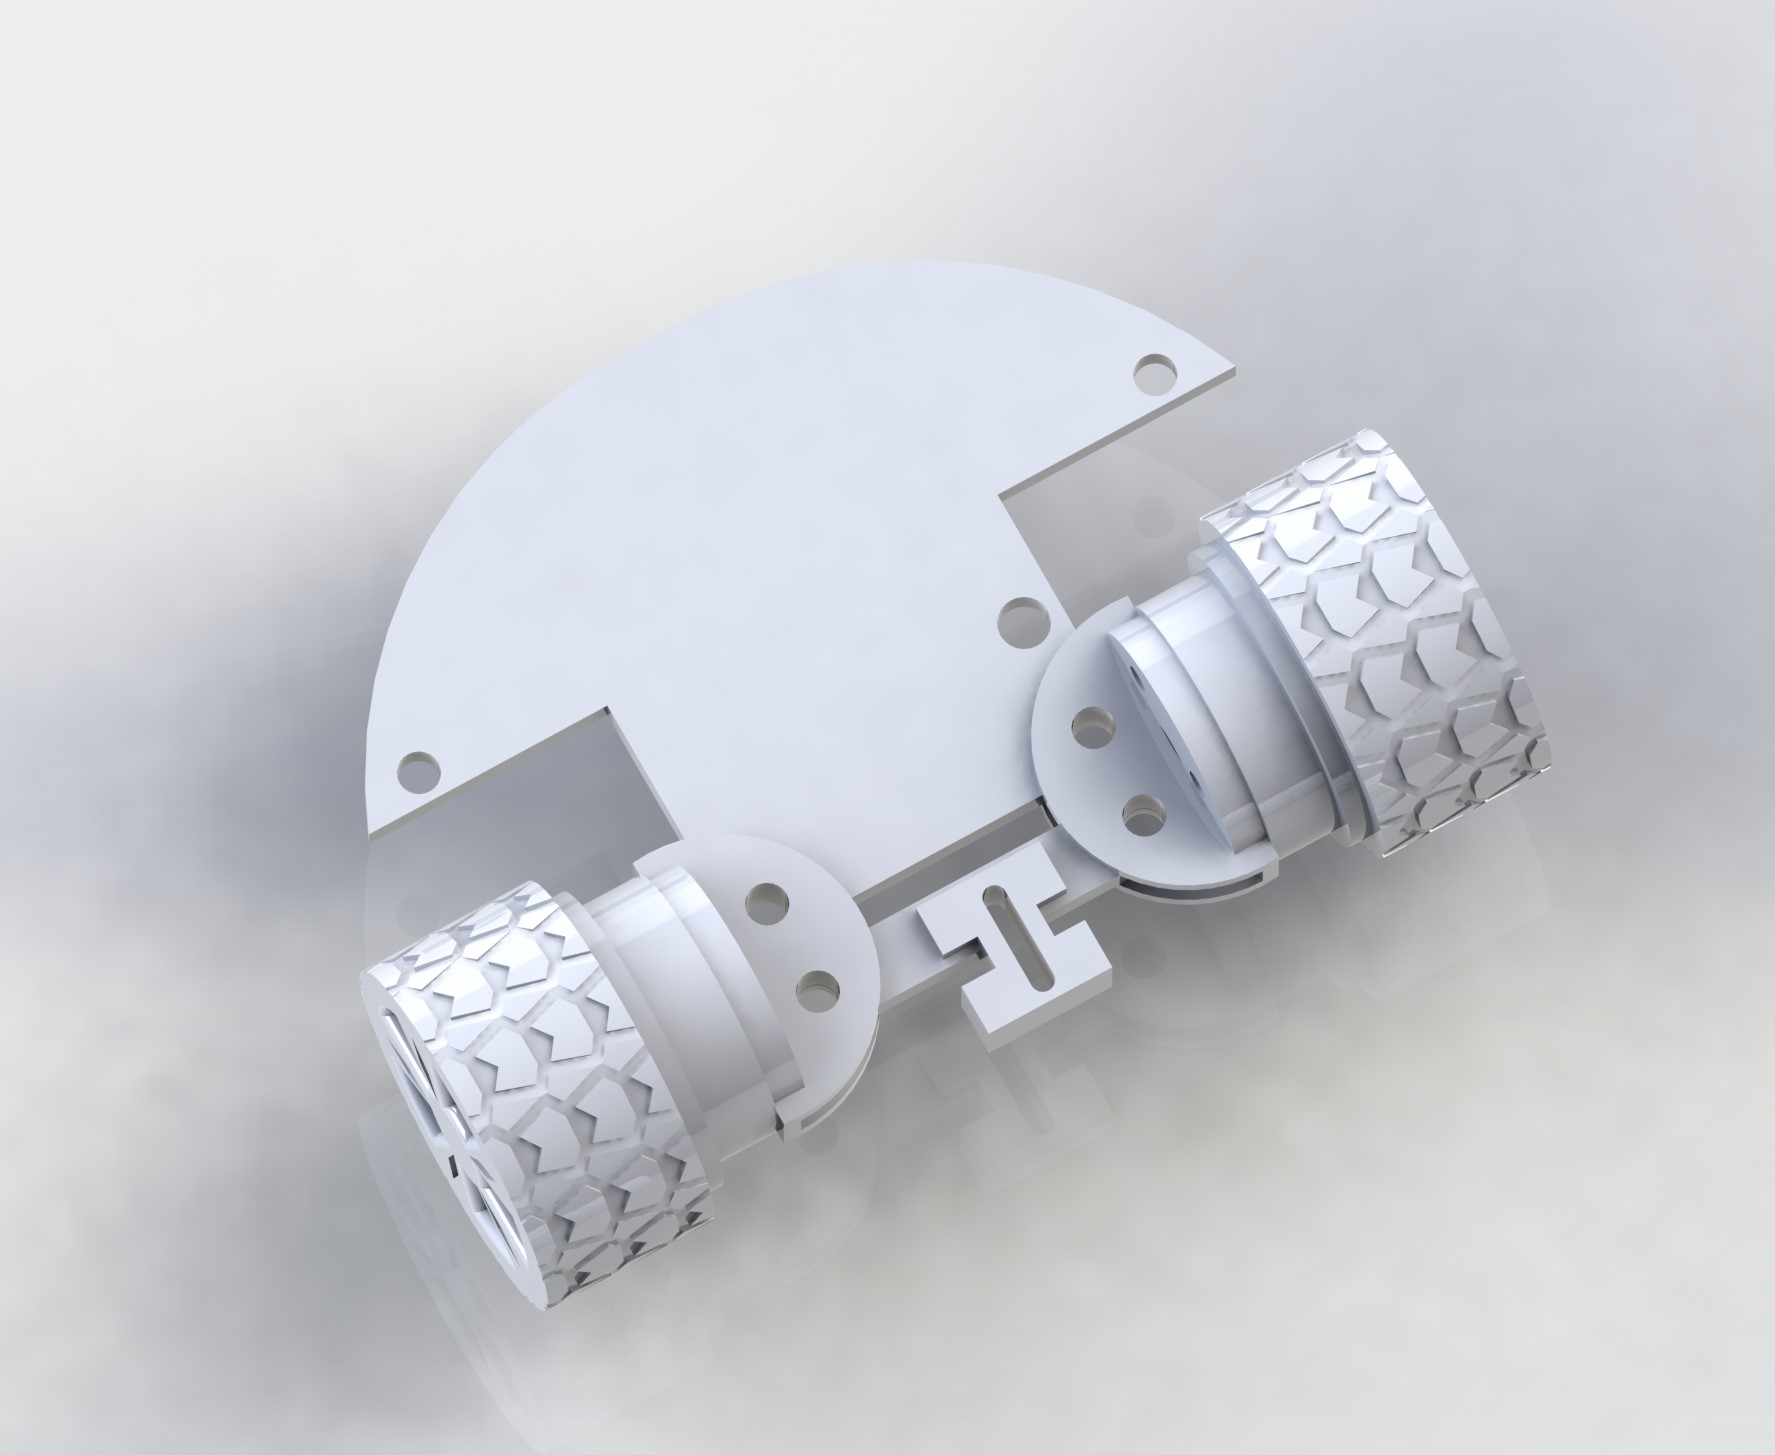
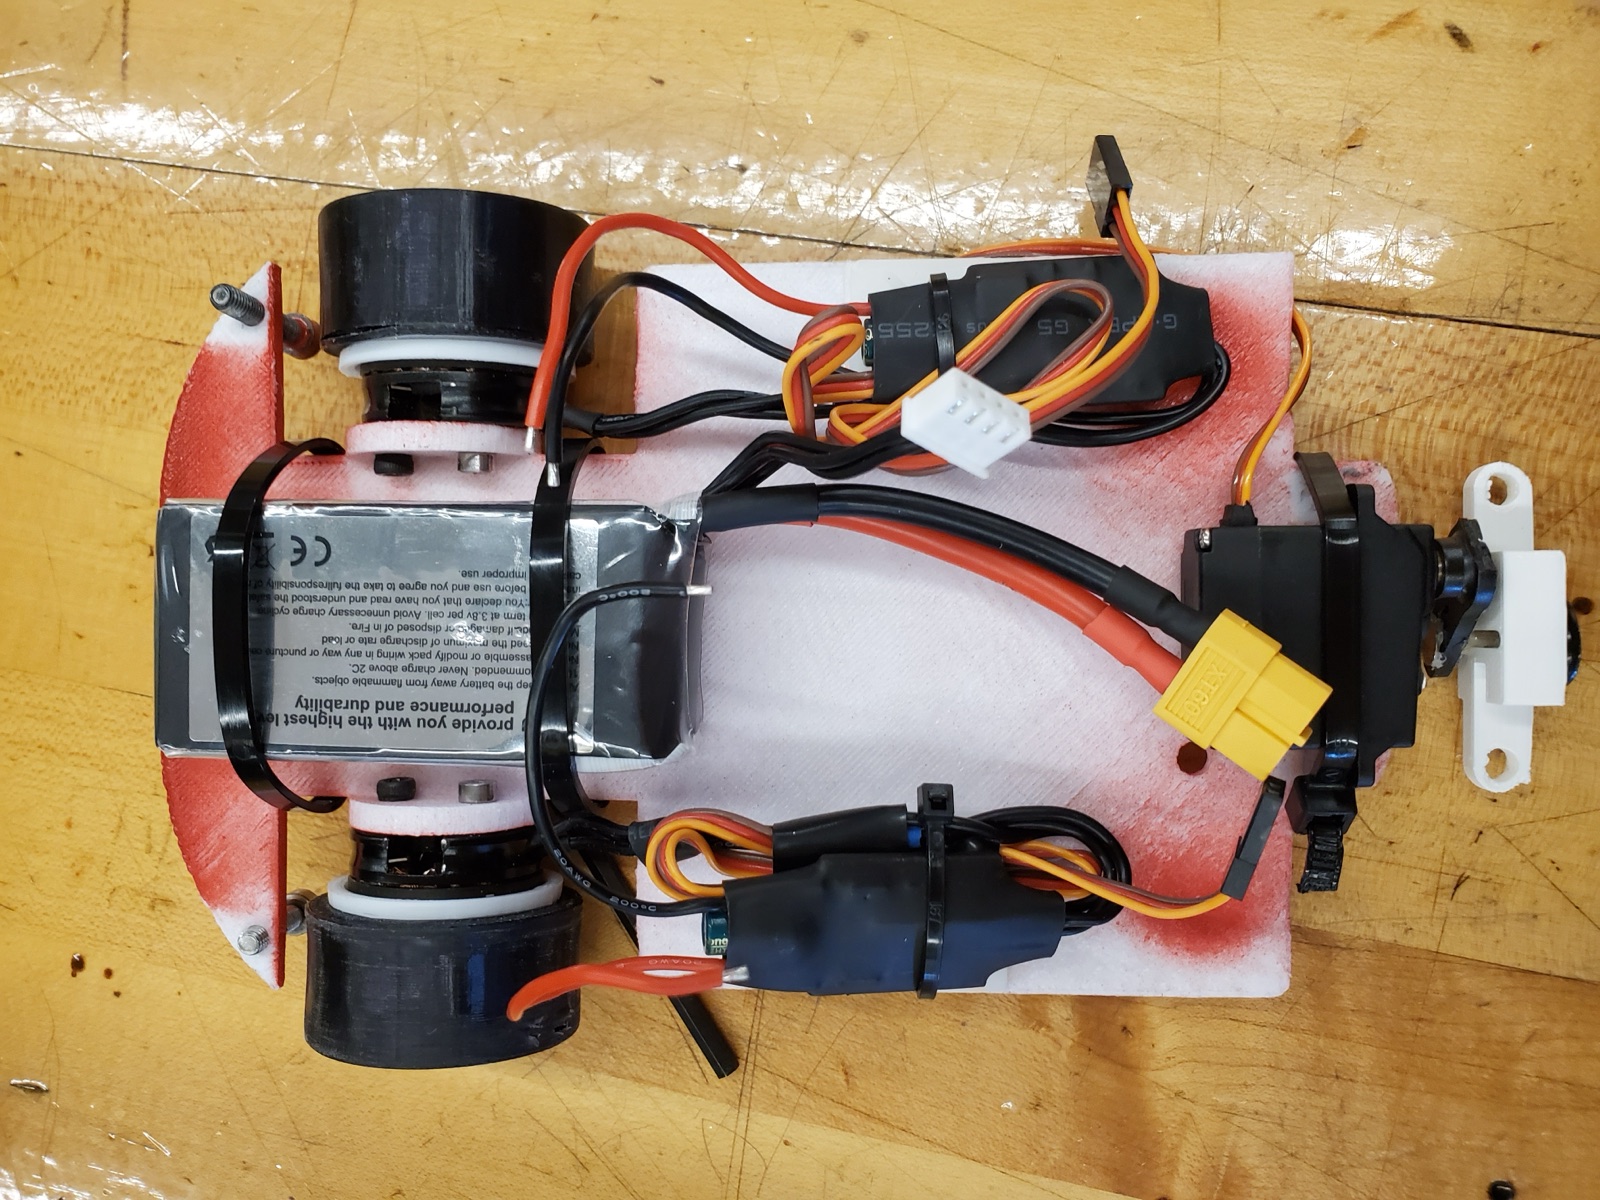
Starting from a modified 3D-printed Enzo Ferrari body, this project integrates a full
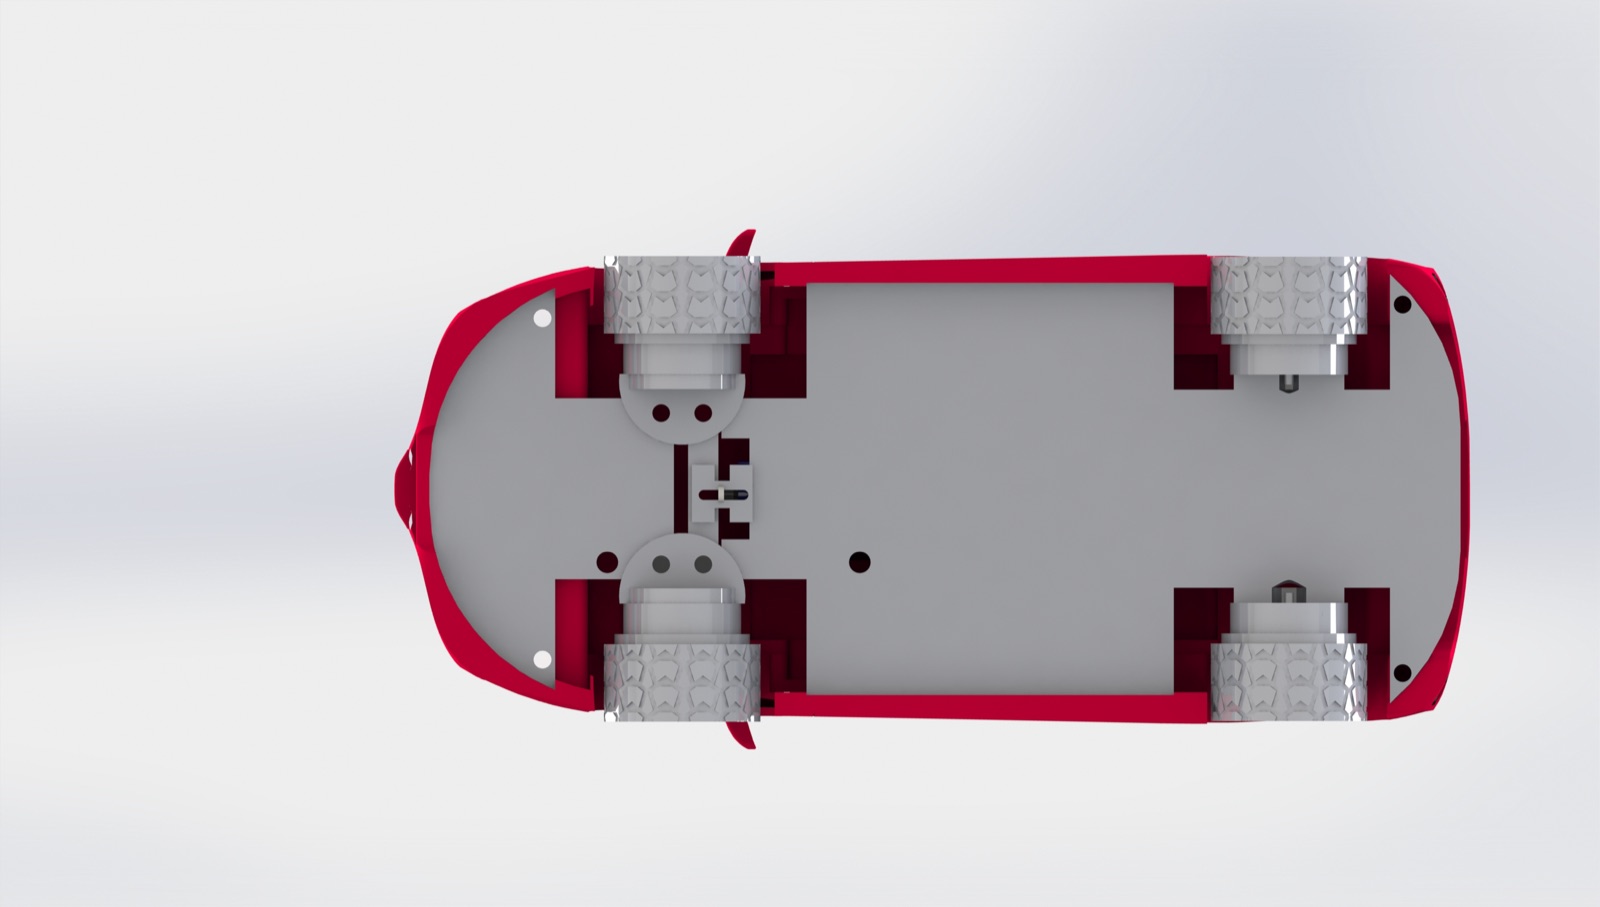
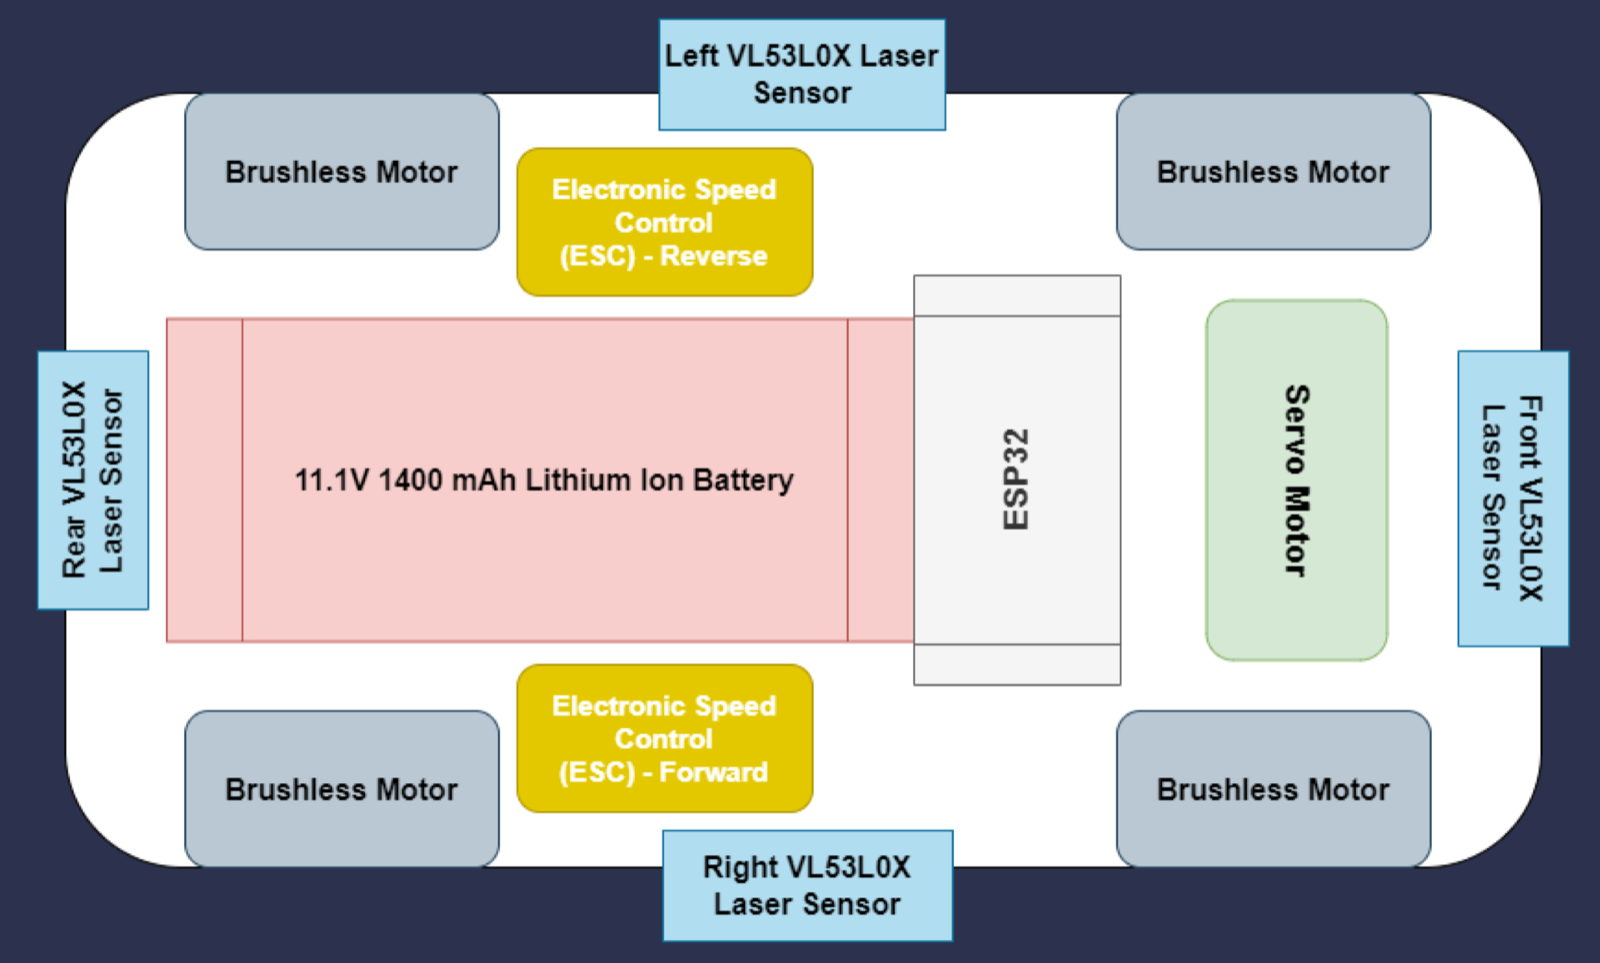
mechatronic system: brushless DC drivetrain, custom breakout PCB, laser obstacle
detection, and Bluetooth control from a smartphone app.
The autonomous parking mode uses four VL53L0X time-of-flight laser sensors to detect
two flanking obstacles and execute a parallel parking maneuver without any human input.
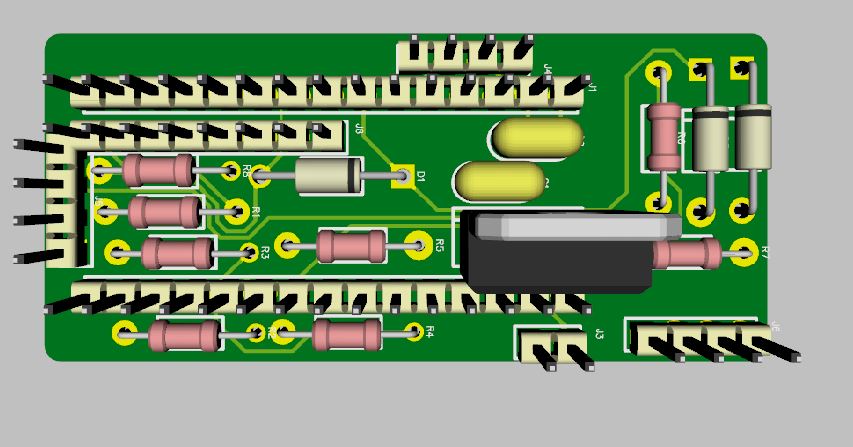
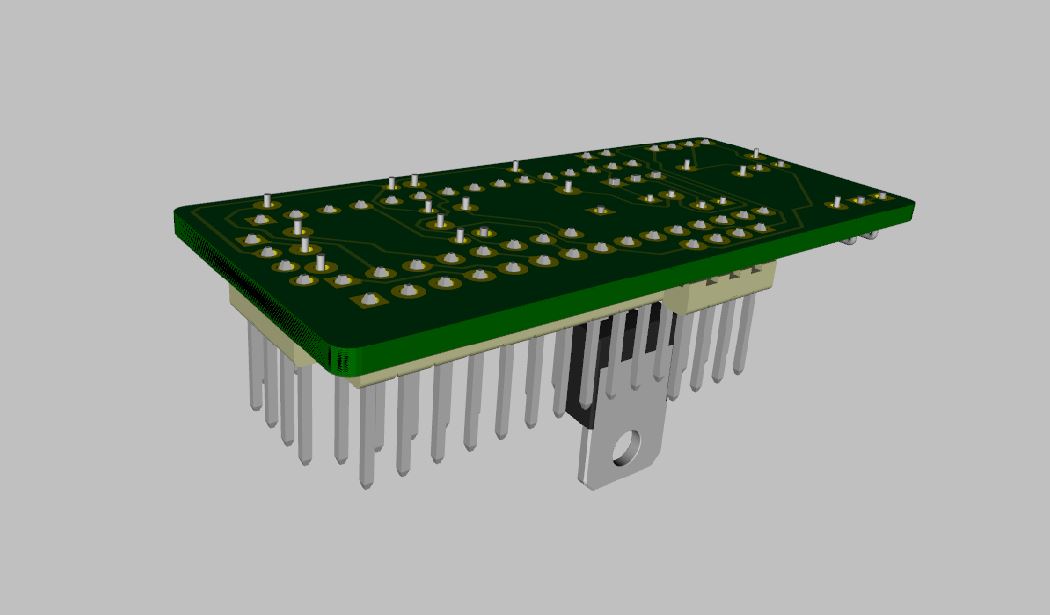
A custom breakout PCB inside the body handles power regulation, sensor interfacing,
and the tail lights.
Motors
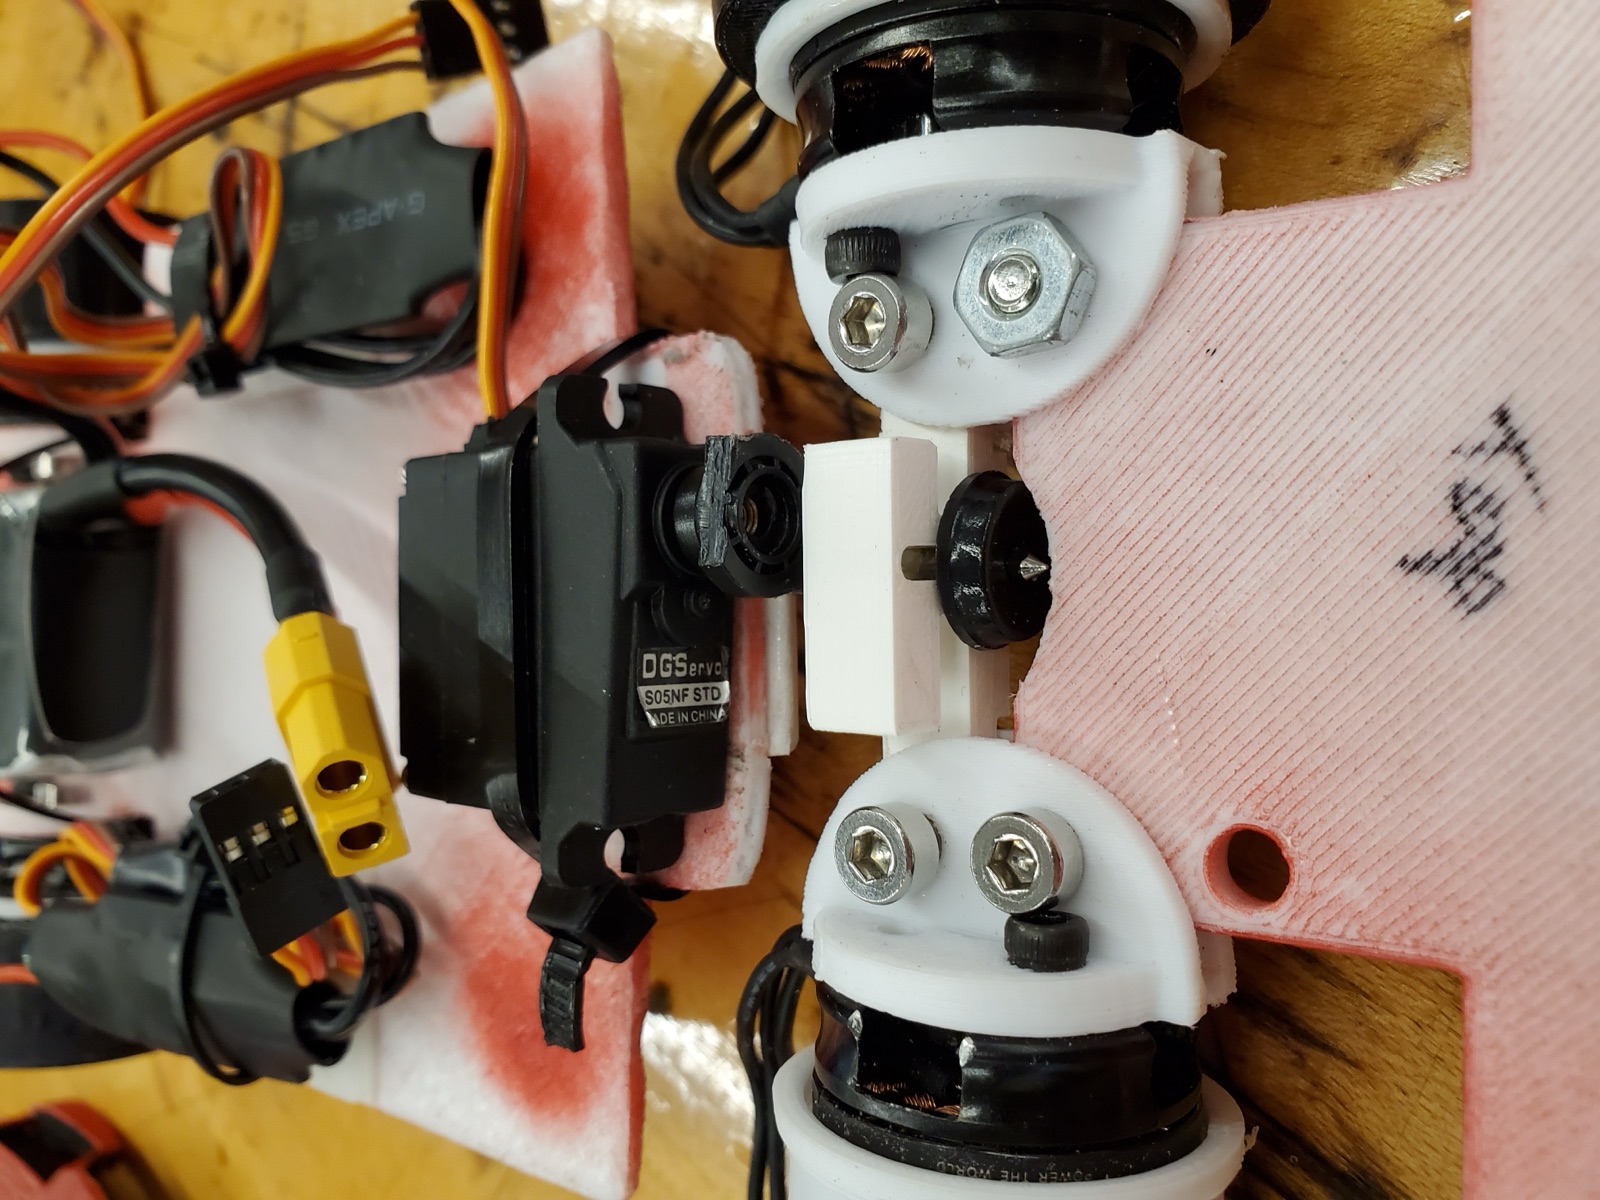
4× 10,000 RPM Brushless DC
ESCs
2× 40A Quadcopter (One-Way)
Steering
20 kg Servo Motor
Sensors
4× VL53L0X ToF Laser
Wireless
ESP32 Bluetooth + Telemetry
PCB
Custom Breakout Board
Body
3D-Printed Enzo Ferrari
Course
Mechatronics (2019) → Adv. Microprocessors (2022)
Collaborators
Matthew Mazalewski · Kim Tran · Wyatt Van Orden